Ozgur S. Oguz
Assistant Professor of Computer Engineering, Bilkent University · Director, Learning for Intelligent Robotic Agents (LiRA) Lab

Office: EA-529, Engineering Bldg.
Dept. of Computer Engineering
Bilkent University, 06800 Ankara
I am an Assistant Professor in the Department of Computer Engineering at Bilkent University, where I lead the Learning for Intelligent Robotic Agents (LiRA) Lab.
Previously, I was a postdoctoral researcher at the Max Planck Institute for Intelligent Systems and the Uni. of Stuttgart (Learning and Intelligent Systems / Machine Learning & Robotics Lab) working with Marc Toussaint, affiliated with the Cluster of Excellence: IntCDC. I received my Ph.D. (summa cum laude) from the Technical University of Munich (TUM). I studied Computer Science at the Uni. of British Columbia (UBC) and Koç University.
Research Interests & LiRA Lab
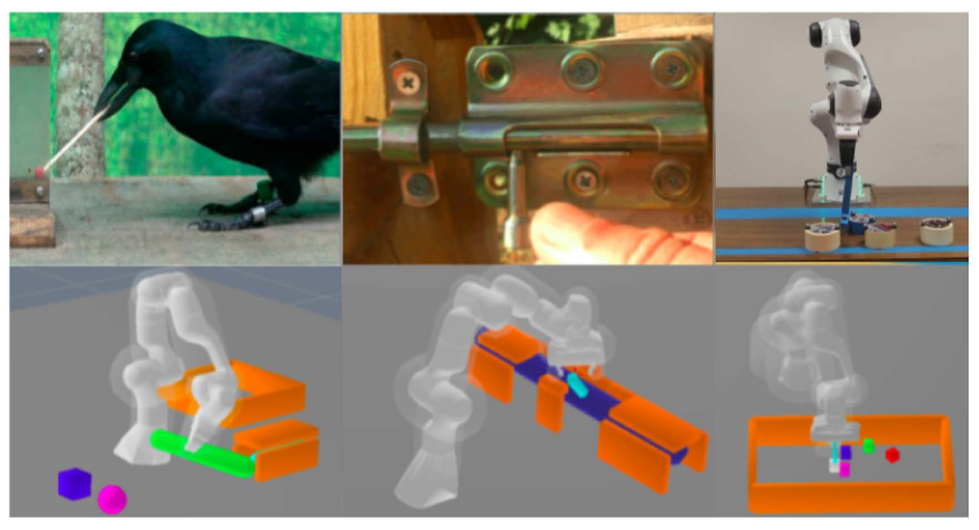
My research sits at the intersection of Robotics, Machine Learning, and Artificial Intelligence. At the LiRA Lab, we specialize in building active, embodied AI agents capable of perceiving, reasoning about, and interacting seamlessly with the physical world:
- Physical Intelligence & Embodied AI: Grounding vision-language models (VLMs) for dexterous manipulation.
- Multi-Arm, Dexterous & Contact-Rich Control: Optimization-augmented reactive control and dynamic tool manipulation.
- Task and Motion Planning (TAMP): Logic-Geometric Programming (LGP), sequential manipulation, and hybrid planners.
- Robot Learning: Deep reinforcement learning, imitation learning, and generative policy synthesis.
Prospective Students & Researchers
news
| Oct 05, 2026 | Two new preprints on diffusion policies are out: P3: Persistent Particle Planning for Constrained Diffusion Control and Reachability-Aware Diffusion Policy Optimization. |
|---|---|
| Sep 14, 2026 | 26-Fall: CS 449 / 549: Learning for Robotics course - course page |
| Jul 01, 2026 | Our paper Interpretable Responsibility Sharing as a Heuristic for Task and Motion Planning is published in Robotics and Autonomous Systems. |
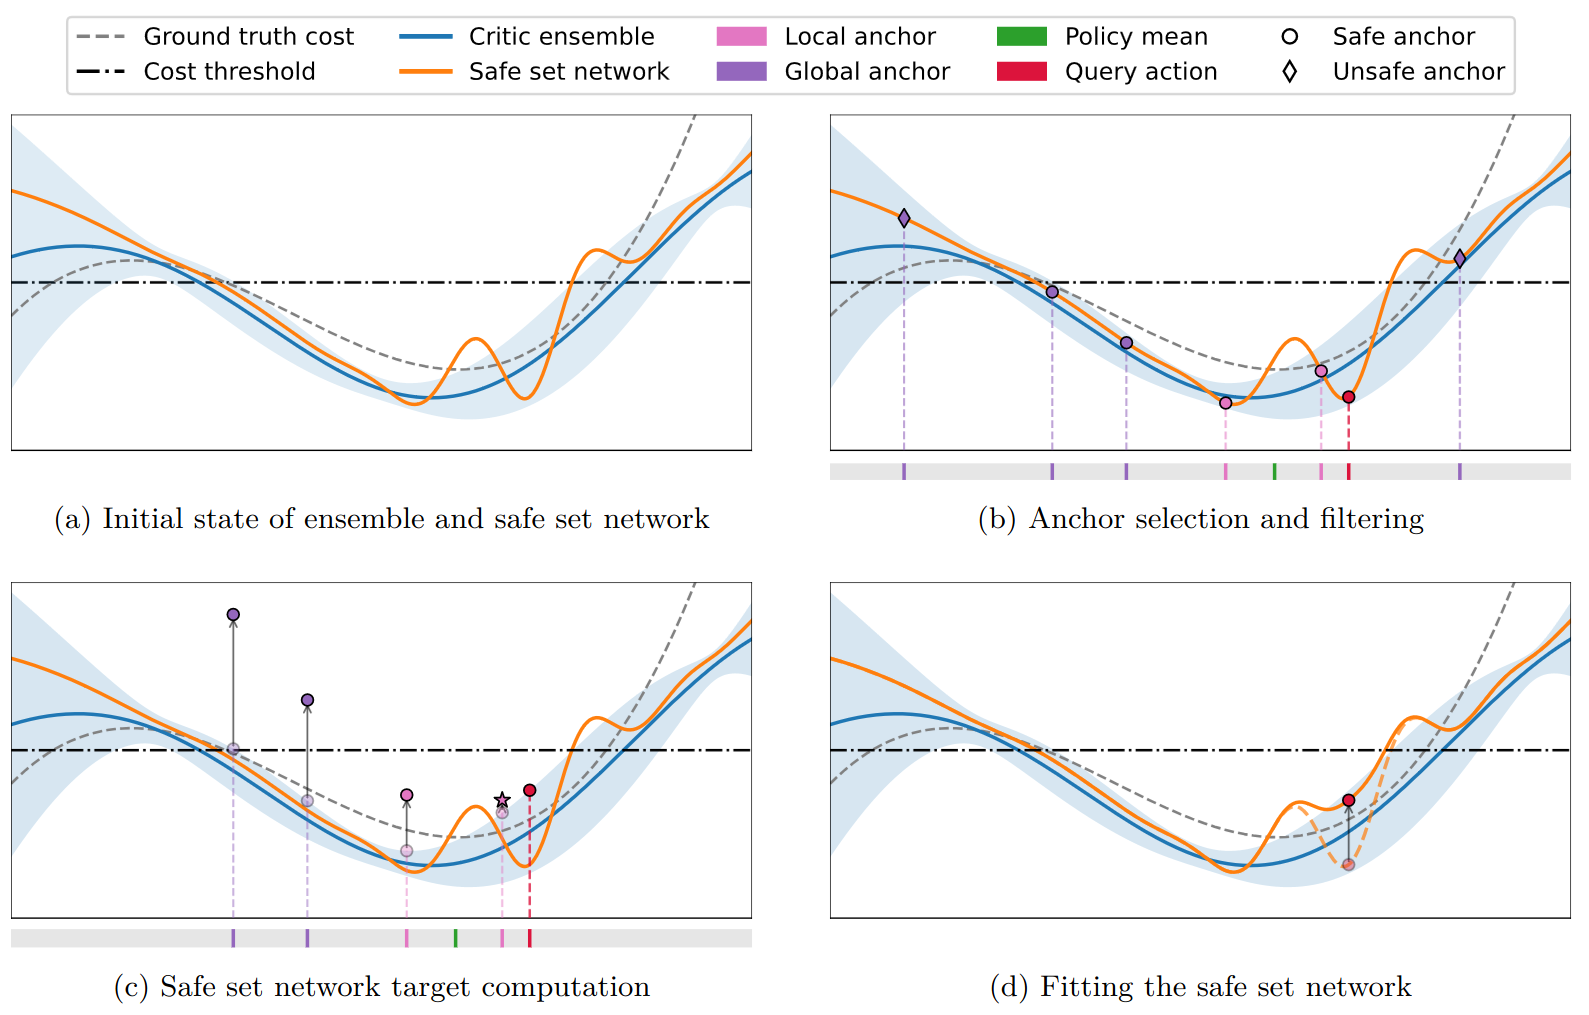
| Jun 01, 2026 | Our paper Uncertainty-Aware Safety Propagation Critics for Safe Reinforcement Learning is accepted to TMLR. |
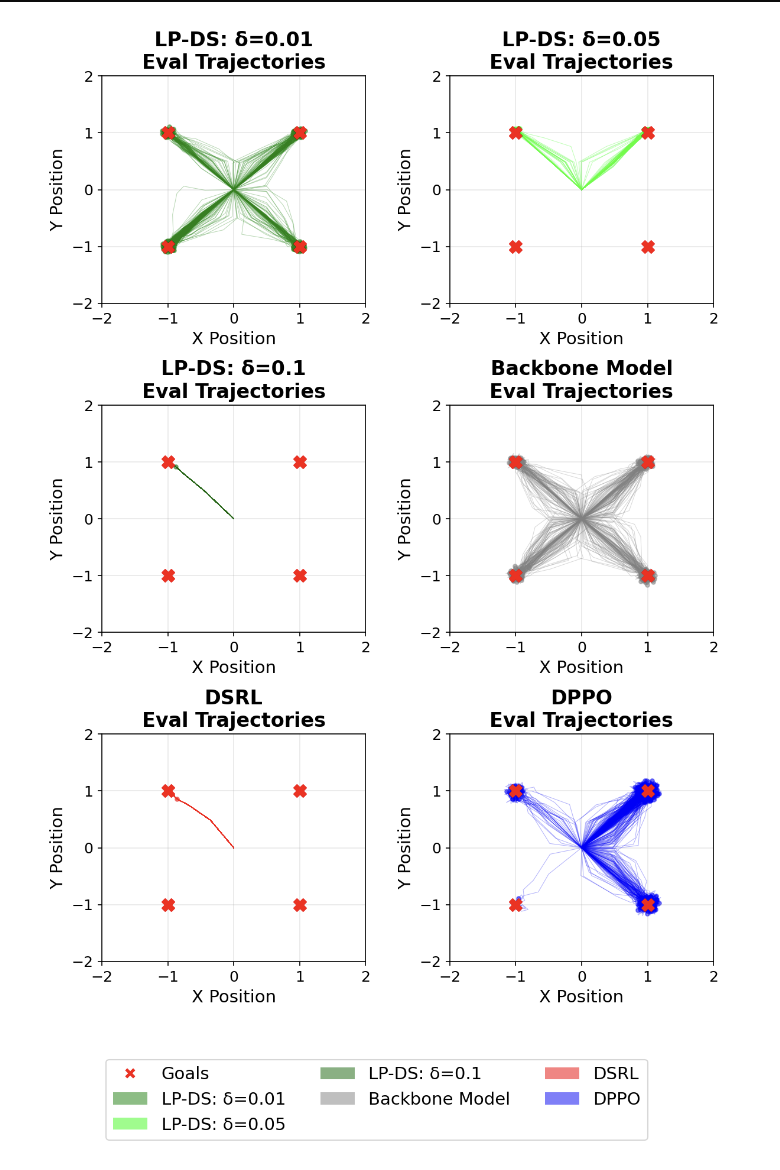
| May 31, 2026 | Our work Lagrangian Perturbation Diffusion Steering: Latent Reinforcement Learning for Generative Policies is accepted to ICML 2026. |
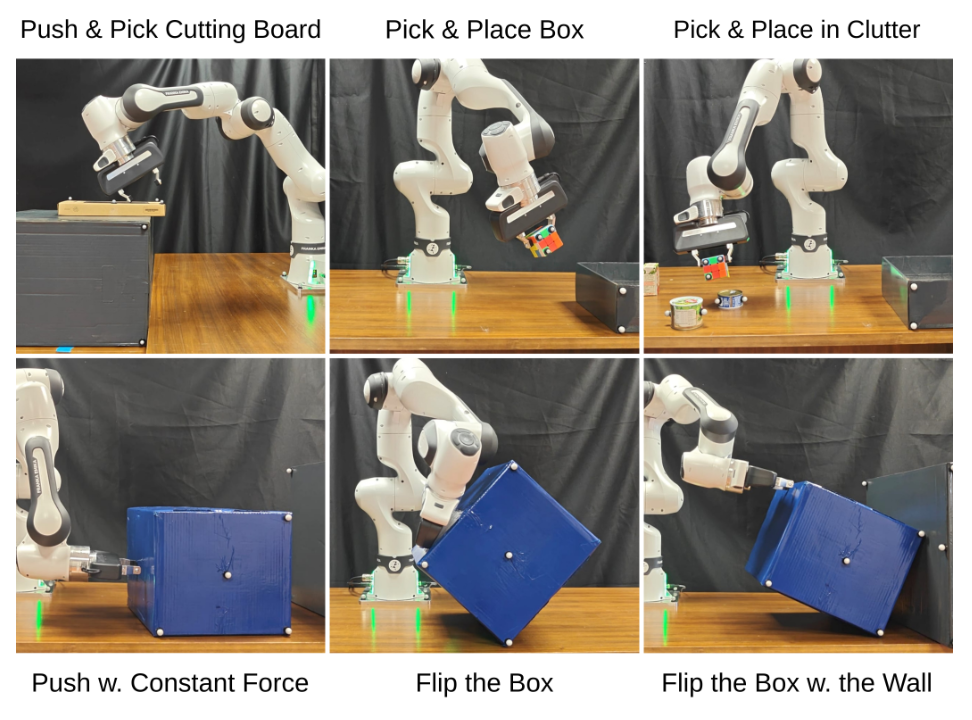
| May 04, 2026 | Our work CoRAL: Contact-Rich Adaptive LLM-based Control for Robotic Manipulation is accepted to RSS 2026. |
| Mar 12, 2026 | New preprint: Push, Press, Slide: Mode-Aware Planar Contact Manipulation via Reduced-Order Models. |